Solution
Smart Wheelchair Control System
Fully autonomous smart wheelchair — auto navigation, path planning, and obstacle avoidance with advanced 3D perception.
QianEasy’s Smart Wheelchair Control is built for full autonomy: the chair plans a route, navigates indoor spaces, and avoids dynamic obstacles — powered by 3D sensing and closed-loop motion control. The story is the platform’s intelligence, not a lab demo with a person at a workstation.
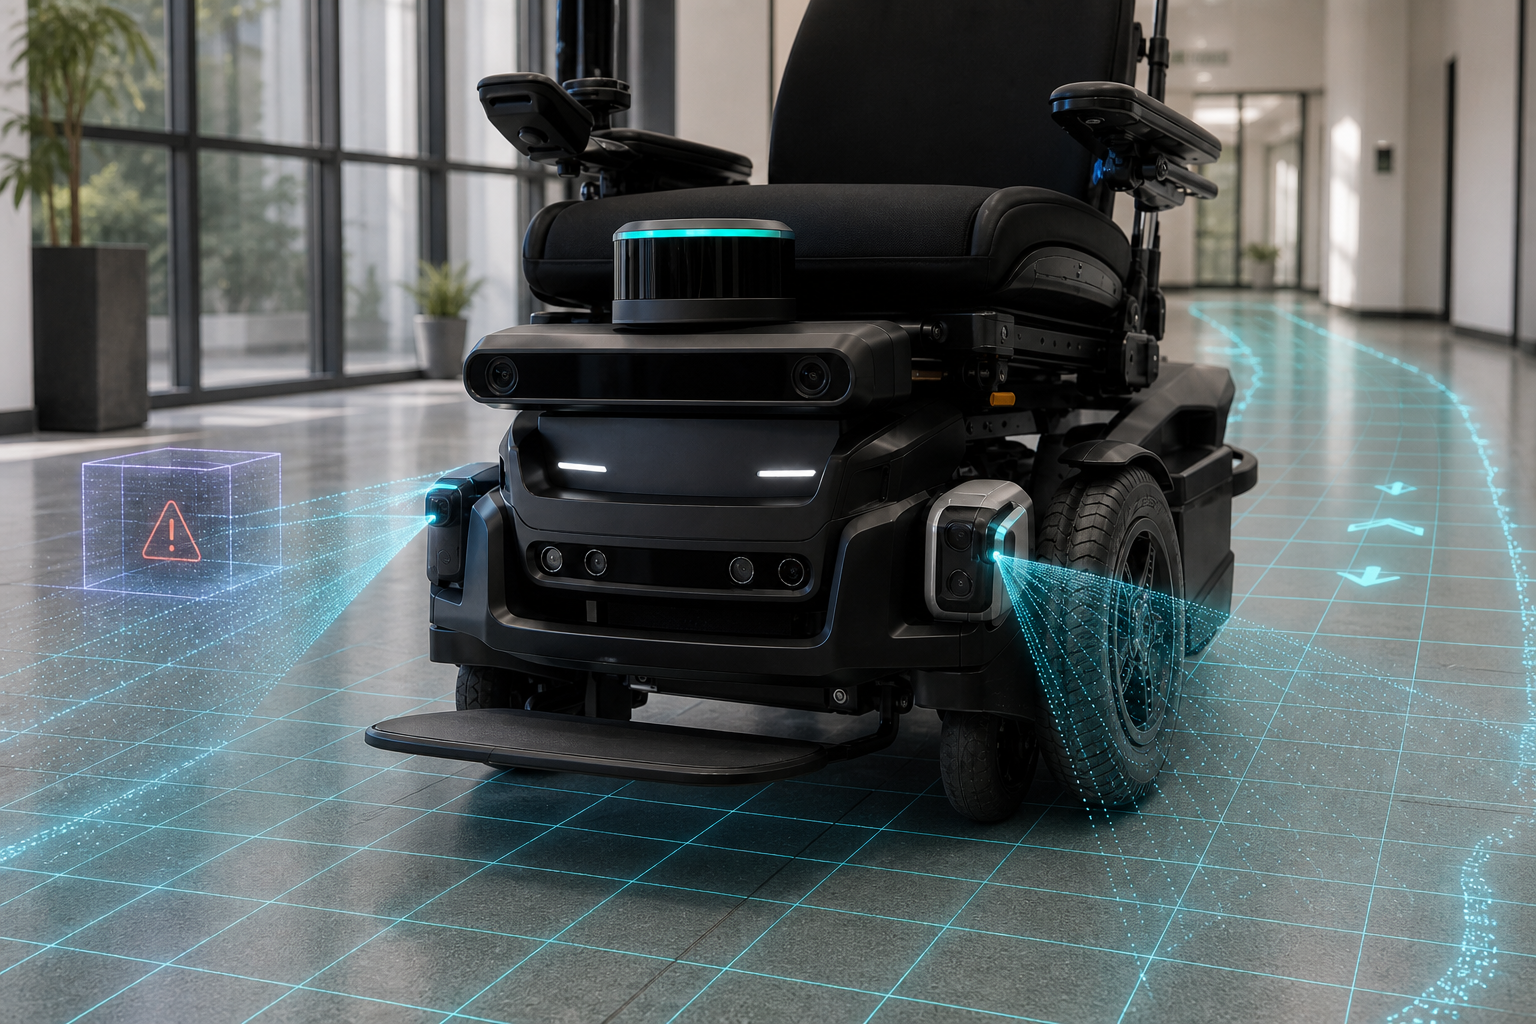
Autonomy stack
We treat the wheelchair as a specialized autonomous mobile platform: map / localize, plan globally, replan locally, and execute smooth, safe trajectories under real corridor constraints.
Core capabilities
- Auto navigation — localize and drive toward destinations in mapped indoor spaces
- Auto path planning — global routes plus local replanning around people and clutter
- Auto obstacle avoidance — real-time 3D perception with soft braking and clearance keeping
- Closed-loop control — comfort-tuned accel / turn profiles with safety watchdogs
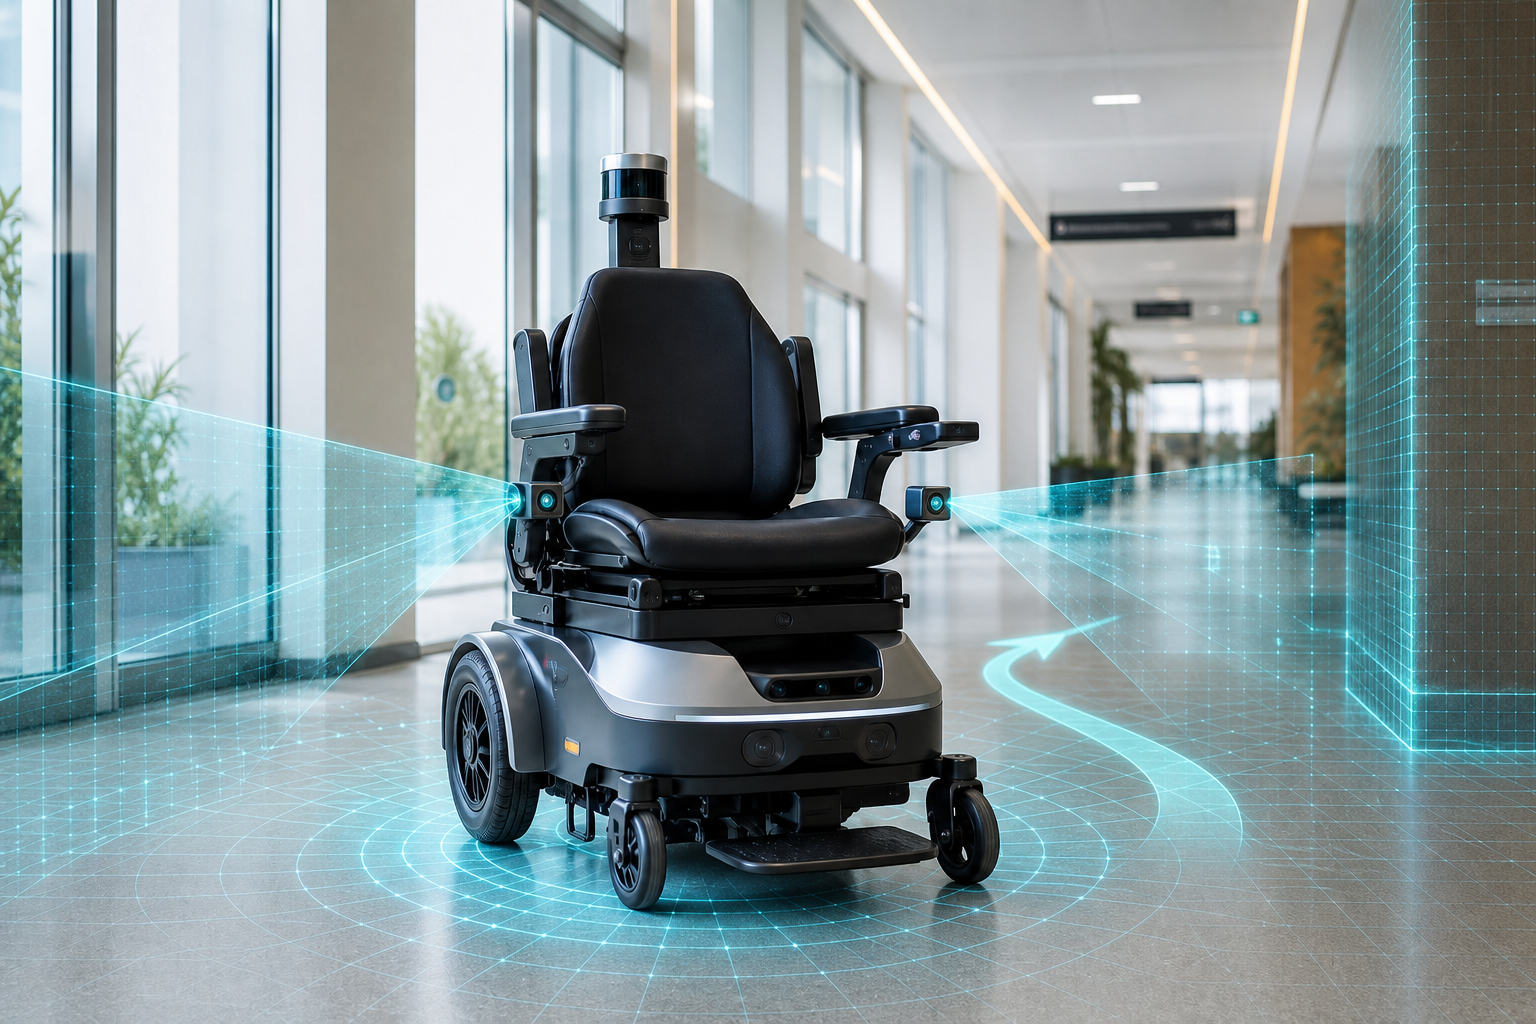
Technology highlights
| Perception | TOF / array LiDAR / camera fusion for geometry and free space |
|---|---|
| Planning | Global path + local dynamic replanning |
| Control | Closed-loop drive with speed / torque limits |
| Safety | Watchdogs, e-stop path, fail-safe stop on sensor loss |
| Integration | Powered wheelchair / mobility base with drive interface |
Start a feasibility review via Contact.