Product
3D TOF Sensor
Industrial time-of-flight depth sensing for navigation, docking, and scene understanding.
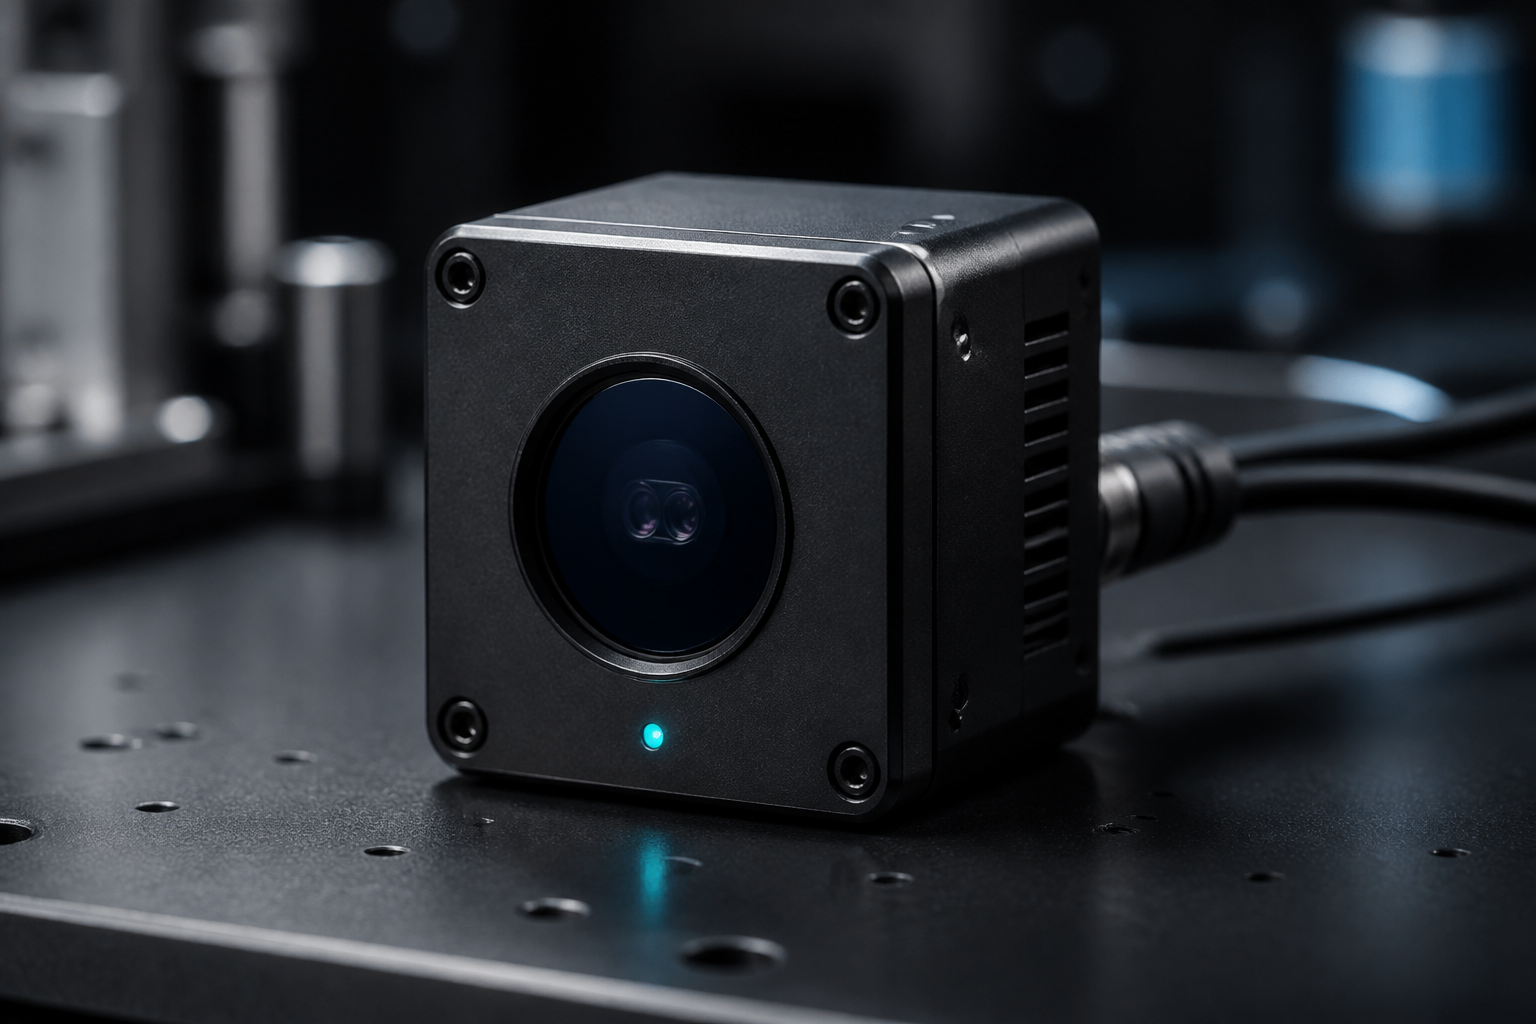
QianEasy 3D TOF Sensor modules convert modulated near-infrared light into dense depth maps — giving mobile robots and industrial vision systems a stable geometric layer for localization, obstacle awareness, and precision docking.
What it solves
Cameras alone struggle with scale and lighting changes. TOF adds metric depth at low latency, so control loops can reason in millimeters rather than pixels. Typical deployments include AMR docking, bin picking assist, cabin / corridor perception, and safety envelopes around moving platforms.
Key capabilities
- Metric depth output — calibrated distance frames for planning and pose estimation
- Low-latency pipeline — suitable for closed-loop motion and docking behaviors
- Indoor / mixed lighting resilience — engineered for factory and indoor logistics environments
- Fusion-ready — pairs with LiDAR, RGB, and IMU in multi-sensor stacks
Typical specifications (configurable)
| Sensing principle | Indirect / direct Time-of-Flight (project configurable) |
|---|---|
| Working range | Short-to-mid range indoor / near-field industrial (application dependent) |
| Output | Depth map / point cloud stream, timestamped frames |
| Interfaces | Ethernet / USB / MIPI-class options per integration package |
| Integration | SDK hooks for calibration, sync, and control-loop consumers |
Integration notes
We provide extrinsic calibration guidance, mounting recommendations, and sample pipelines that feed navigation and visual positioning controllers. For airport inspection, wheelchair platforms, or golf-cart following stacks, TOF often serves as the near-field depth layer alongside longer-range LiDAR.
Talk to engineering via Contact.